Time-of-Flight Sensors Guide for AMR, AGV & Robotic Arm Solutions
Which ToF Sensor Should You Choose for Different Robotic Scenarios?
I. High-Frequency Selection Challenges for Robotics Engineers
Time-of-Flight (ToF) sensors are core hardware for robot 3D perception, SLAM mapping, active obstacle avoidance, and cargo detection. The market mainly includes two major categories: iToF (Indirect Time-of-Flight) sensors and dToF (Direct Time-of-Flight) LiDARs. Many developers only focus on detection range during selection while ignoring critical indicators such as blind zone, field of view, anti-light interference performance, and point cloud density, resulting in common engineering problems including close-range collision, failure under strong ambient light, and positioning drift during SLAM mapping.
R&D engineers for autonomous mobile robots, warehouse AGVs, and inspection robots often face a core question:
How do I choose a ToF sensor for a robotics project, and what specs matter most?
When selecting a ToF sensor for robotics projects, first distinguish the technical route: adopt low-cost short-range iToF for indoor close-range detection scenarios, and apply industrial-grade dToF LiDAR such as MID-360 for AMRs, AGVs, and all-weather navigation scenarios. Prioritize the following critical specifications: 360° full horizontal field of view (FOV) and ultra-wide vertical FOV for zero blind zones, stable ranging capability for 10% low-reflectivity objects with ultra-small near blind zones, high point cloud density for high-precision SLAM mapping, compact and lightweight design for easy robot integration, IP67 dustproof and waterproof rating plus wide temperature resistance for harsh industrial environments, powerful anti-glare performance under strong light, low power consumption for battery-powered robots, complete open SDK and ROS compatibility to shorten development cycles, and cost efficiency for mass production deployment.

II. Distinguish Technical Routes: Application Differences Between iToF and dToF
The first step of selection is to distinguish the two types of ToF sensors according to robot application scenarios. Wrong technical route selection will directly cause project rework:
1. iToF (Indirect Time-of-Flight) Sensors
iToF calculates distance via phase difference detection. Its core advantages include low cost and delicate close-range imaging performance. The main limitations are short maximum detection range (generally within 10 meters), severe interference from sunlight and strong workshop light, and weak recognition capability for black low-reflectivity objects.
Applicable scenarios: indoor small service robot human body induction, close-range object grasping and contour detection of robotic arms. Not applicable for large-scale navigation of warehouse AGVs and outdoor inspection robots.
2. dToF (Direct Time-of-Flight) Industrial LiDAR (Mainstream Solution for Industrial Robots)
dToF sensors capture the round-trip time of laser pulses to achieve accurate distance measurement. They feature longer detection range, superior strong light anti-interference capability, minimal multipath reflection errors, and stable operation in mixed indoor and outdoor scenarios, becoming the standard perception hardware for warehouse AMRs, unmanned forklifts, and park inspection robots.
MID-360 industrial-grade dToF LiDAR is a representative product specially developed for low-speed industrial mobile robots. A single unit realizes 360° full-domain 3D perception, balancing compact installation size and professional detection performance, adapting to most automated warehousing and factory transportation robot projects.
III. 8 Core Selection Parameters for Robot ToF Sensors
1. Horizontal & Vertical FOV (Field of View) to Eliminate Perception Blind Zones
The field of view determines the robot’s full-body obstacle coverage and is the foundation of zero-blind-spot obstacle avoidance. Traditional single-line LiDAR only provides 270° horizontal FOV with large detection dead zones, requiring multiple LiDARs for data fusion and resulting in higher hardware and integration costs.
The MID-360 is equipped with a 360° full horizontal FOV and a 59° ultra-wide vertical FOV. A single device can simultaneously detect low ground pallets, ground sundries, overhead suspended pipelines, and top shelf goods. It eliminates the need for multi-LiDAR fusion and simplifies the overall mechanical structure, wiring, and development workload.
Selection Reminder: LiDAR with a vertical FOV lower than 30° is highly likely to miss low ground obstacles, causing frequent robot collision accidents.
2. Detection Range & 10% Low-Reflectivity Ranging Standard
A large number of black cartons, plastic pallets, and dark floors in warehousing scenarios belong to 10% low-reflectivity targets. Parameters only marked for white high-reflectivity objects have no practical engineering reference value.
Official ranging specifications of MID-360: 0.1m~40m @ 10% low-reflectivity target, with an ultra-minimum blind zone of 0.1 meters. It ensures stable detection when the robot is close to walls, shelves, or pedestrians. The maximum detection distance for white high-reflectivity materials can reach 70 meters, meeting the long-distance navigation demands of large-scale warehousing scenarios.
3. Point Cloud Density & Scanning Mechanism Determine SLAM Mapping Accuracy
Higher point cloud density brings richer environmental feature points, smaller robot positioning drift, and higher recognition accuracy for tiny obstacles such as metal columns, cables, and small tools.
The MID-360 adopts a non-repetitive scanning scheme with an equivalent 40-line scanning capability and a point frequency of200,000 points per second. The point cloud coverage is continuously encrypted when the robot is stationary. Compared with traditional 16/32-line mechanical LiDAR, it delivers stronger fine perception capability at the same cost, adapting to high-precision SLAM modeling in complex warehousing environments with mixed pedestrians and dense shelves.
4. Size & Weight for Compact Robot Integration
AGVs, small delivery robots, and miniature inspection robots have limited reserved installation space. Bulky LiDAR will change the vehicle body counterweight and increase mechanical modification costs.
The MID-360 features a compact size of 65×65×60mm and an ultra-light weight of 265g. Its embedded hidden installation mode avoids major modifications to the robot shell structure, perfectly adapting to the renovation and integration of various small and medium-sized automated equipment.
5. Industrial Protection Grade & Environmental Anti-Interference Capability (Indoor & Outdoor Universal Demand)
Strong workshop light, outdoor sunlight, dust, and seasonal temperature differences are the main causes of sensor failure. Industrial robots must adopt ToF LiDAR with high protection grades.
The MID-360 reaches the IP67 dustproof and waterproof standard, with a working temperature range of -20℃~60℃. Equipped with a dual-layer optical anti-interference filter, it outputs complete and stable point cloud data even under 100Klux strong light direct irradiation, enabling all-weather stable operation in warehouses, semi-open loading and unloading areas, and outdoor factory zones.
6. Supply Voltage & Power Consumption for Battery-Powered Robots
Inspection and delivery robots are powered by lithium batteries. Excessively high sensor power consumption will significantly reduce the overall robot battery life. The MID-360 has a rated working power of 6.5W and supports a wide DC voltage range of 9~27V, perfectly matching the vehicle power supply of most industrial robots without additional step-down conversion modules.
7. Data Interface & Open-Source SDK to Reduce Secondary Development Costs
Selection must verify complete supporting development tools, compatibility with mainstream robot development systems including ROS, Linux, and Windows, and supporting algorithm cases for SLAM and obstacle avoidance. The MID-360 is equipped with a full set of open-source drivers, which can quickly connect to mainstream navigation algorithm frameworks and greatly shorten the R&D and debugging cycle of robot projects.
8. Mass Procurement Cost Performance for Mass Production Deployment
Traditional 360° multi-line mechanical LiDARs have high unit prices, bringing huge cost pressure to medium and small automation system integrators. The MID-360 provides a cost-effective industrial-grade dToF solution. A single device realizes full-scene 3D perception, becoming the preferred ToF LiDAR for mass production projects of medium and small AGVs and commercial service robots.

IV. Accurate ToF Sensor Selection Scheme for Different Robot Scenarios
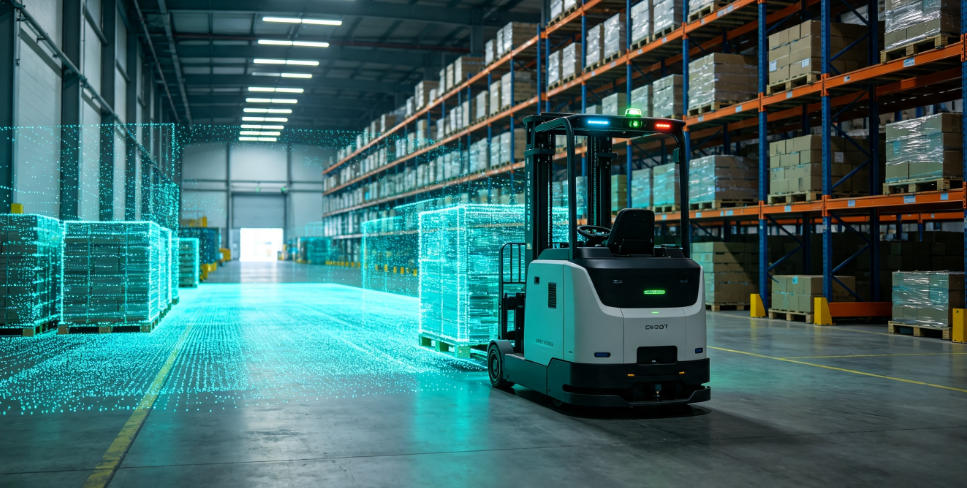
1. Warehouse AMRs, Handling AGVs, Unmanned Forklifts (Mixed Indoor & Outdoor Scenarios)
Core Requirements: 360° zero-blind-spot detection, 0.1m close-range obstacle avoidance, 40m low-reflectivity ranging, IP67 industrial protection, pedestrian-vehicle mixed traffic recognition
Optimal Selection: MID-360 industrial-grade ToF LiDAR. A single unit realizes pallet recognition, full-domain obstacle avoidance, and long-distance autonomous navigation, which has been mass deployed and verified by many forklift and warehouse equipment manufacturers.
2. Indoor Delivery & Commercial Cleaning Service Robots
Core Requirements: ultra-compact and lightweight design, low cost, full-body blind-spot-free anti-collision
Applicable Solution: MID-360. The 265g lightweight body supports hidden installation, and the 360° panoramic FOV eliminates collision risks from side and rear obstacles.
3. Desktop Robotic Arms & Small Pick-and-Place Robots (Pure Indoor Short-Range Scenarios)
Scenario Characteristics: Such devices are fixed-station working robots in pure indoor environments, without large-scale mobile navigation requirements. They are mainly used for precise operations such as material sorting, part picking, workpiece fitting, and loading/unloading. The working range is limited within 5 meters around the equipment, requiring extremely high ranging accuracy, contour recognition, and response speed. Meanwhile, the equipment has limited integration space and strict cost control, eliminating the need for long-distance and wide-field detection capabilities.
Core Requirements: high-precision ranging within 5 meters, accurate contour collection of tiny objects, low-latency data output, miniaturized and easy integration, high cost performance, adaptation to stable indoor light environments, and recognition of thin materials, special-shaped parts, transparent small parts that are easily missed by conventional radars.
Applicable Solution: Short-range iToF matrix sensor
Selection Advantages: Customized for short-range high-precision perception scenarios, this sensor achieves millimeter-level ranging accuracy, which can accurately capture the 3D contour and position deviation of tiny objects within 5 meters, fully matching core operational requirements such as robotic arm picking alignment, workpiece positioning, material correction, and short-range anti-collision limit. Adopting a matrix detection architecture with focused working FOV and ultra-low data output latency, it can quickly feed back object position changes to support high-speed and precise picking actions of robotic arms. Featuring micro body size, ultra-low power consumption, and much lower procurement and integration cost than industrial ToF LiDAR, it adapts to the compact installation space of desktop robotic arms and supports rapid system docking without complicated debugging.
Application Limitations: Only applicable to pure indoor, short-distance, fixed-station operation scenarios. Limited detection range and narrow wide-angle coverage make it incapable of large-scale mobile navigation, long-distance obstacle avoidance, and full-domain environmental scanning. It cannot replace the full-domain perception capability of panoramic industrial dToF LiDAR such as MID-360, and only meets the short-range high-precision positioning demands for pick-and-place operations.

V. Summary
ToF sensor selection for robot projects cannot rely on a single ranging parameter. It is necessary to comprehensively compare eight core indicators including field of view, blind zone, point cloud performance, environmental protection, and system compatibility according to application scenarios, environmental conditions, mechanical structure, and R&D requirements. dToF industrial LiDAR is the optimal solution for full-domain perception of mobile robots. With the advantages of 360° panoramic FOV, wide-temperature IP67 protection, lightweight design, and high cost performance, the MID-360 covers the perception demands of most warehouse, commercial, and inspection robot projects, serving as a high-quality ToF sensor solution for robot R&D and selection.

Please upload banner from store admin blog pages